ENGINEERING THE AUTONOMOUS FUTURE.
41.0082° N, 28.9784° E • SECTOR 01 // VELTRON UNIT X1 & REVEROB OS
Autonomous Field Robotics & Control Systems Built in the Lab.
From 6061 aluminum chassis fabrication and embedded sensor boards to YOLOv8 computer vision and the REVEROB OS command interface, we design and build every layer in-house.
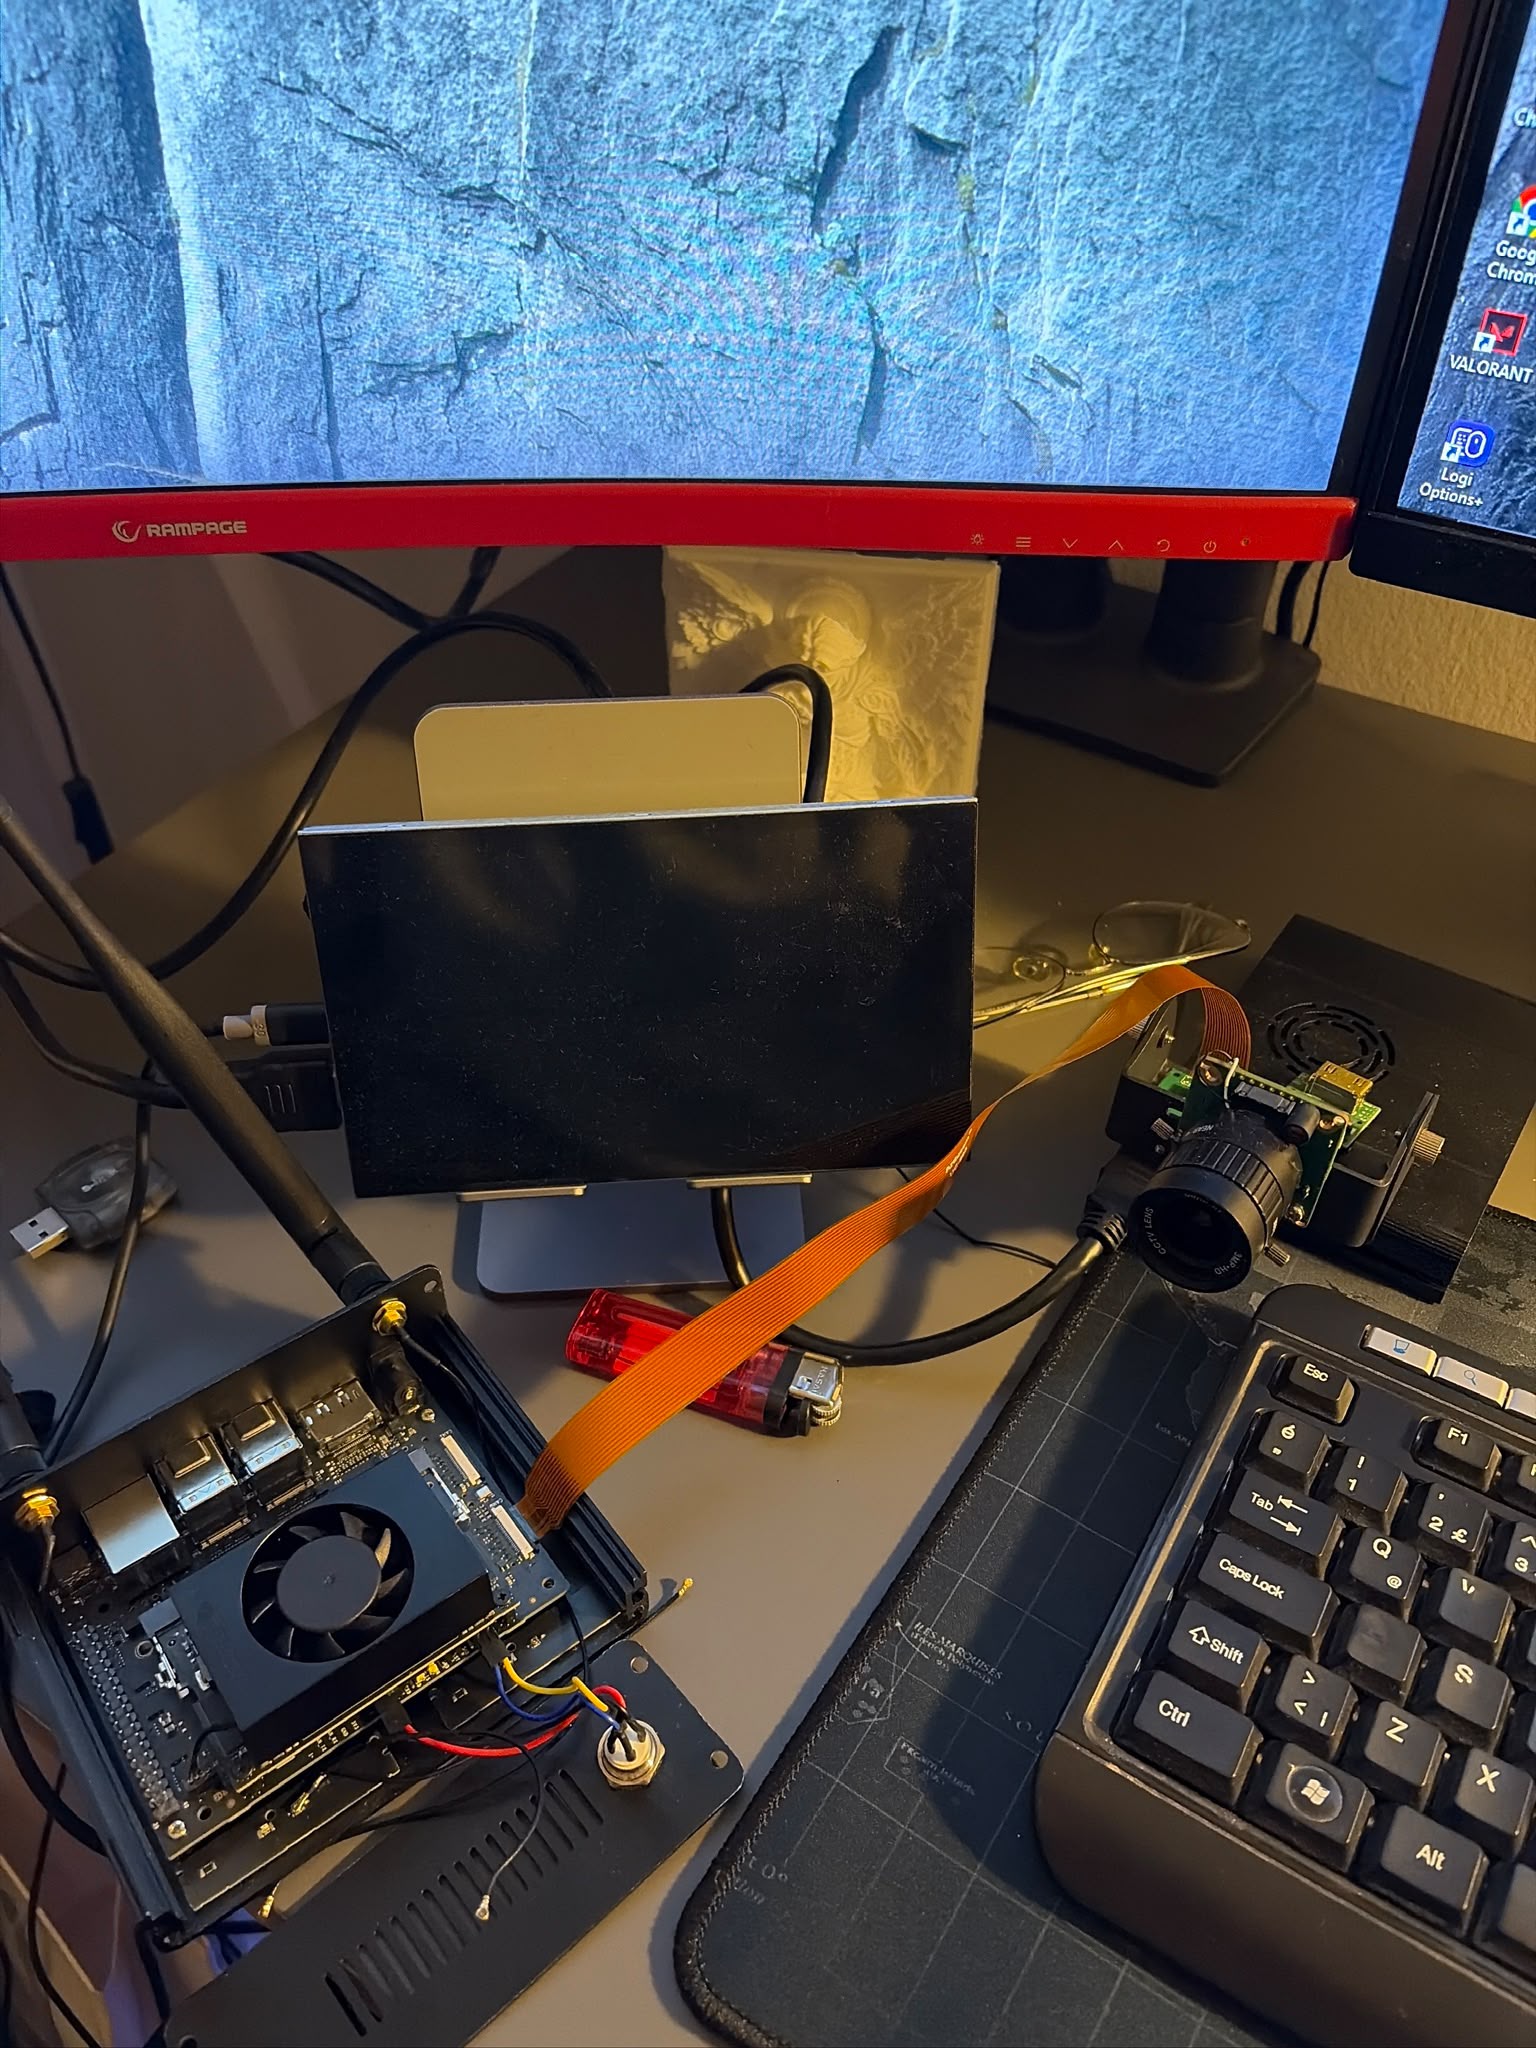
Prototype Activation & System Calibration
Every robotic platform we build undergoes power distribution checks, optical/thermal sensor alignment, and REVEROB OS telemetry verification before field trials.
OPT-01 — Sony IMX477 CSI Camera Module
High-Resolution Optical Imaging Sensor (CSI-2)
Real-time visual perception, YOLOv8 object detection, target tracking, and live operator video streaming.
Streams low-latency raw video frames over MIPI CSI-2 ribbon bus into the Raspberry Pi 5 and target Jetson Orin Nano computer vision pipeline.
Uniting Hardware Engineering, Artificial Intelligence & Autonomous Systems.
REVEROB (Robotic Engineering & Versatile Exploration Response Operations Base) is an engineering and technology initiative focused on developing intelligent robotic platforms, artificial intelligence systems, autonomous technologies, embedded computing, and integrated engineering software.
To design and develop intelligent, modular and reliable technologies by integrating robotics, AI, embedded systems and advanced engineering.
To establish a scalable technology ecosystem for next-generation autonomous robotic systems and intelligent machines.
REVEROB ROBOTICS
Intelligent Robotics & Autonomous Platforms
- Mobile robotics
- Tracked robotic platforms
- Mechanical design (6061 Aluminum)
- Multi-sensor integration
- Autonomous robotics research
REVEROB SYSTEMS
Intelligent Software & Control Infrastructure
- REVEROB OS
- Robot & mission management
- AI integration (YOLOv8)
- Software architecture (React + Electron)
- OTA update infrastructure
REVEROB TECHNOLOGIES
Research, Development & Emerging Technologies
- Embedded systems (Jetson / RPi / ESP32)
- Electronics & sensor interfaces
- Computer vision systems
- Hardware-software integration
- Engineering prototype development
Six Engineering Disciplines, One Integrated Architecture.
Robotics Engineering
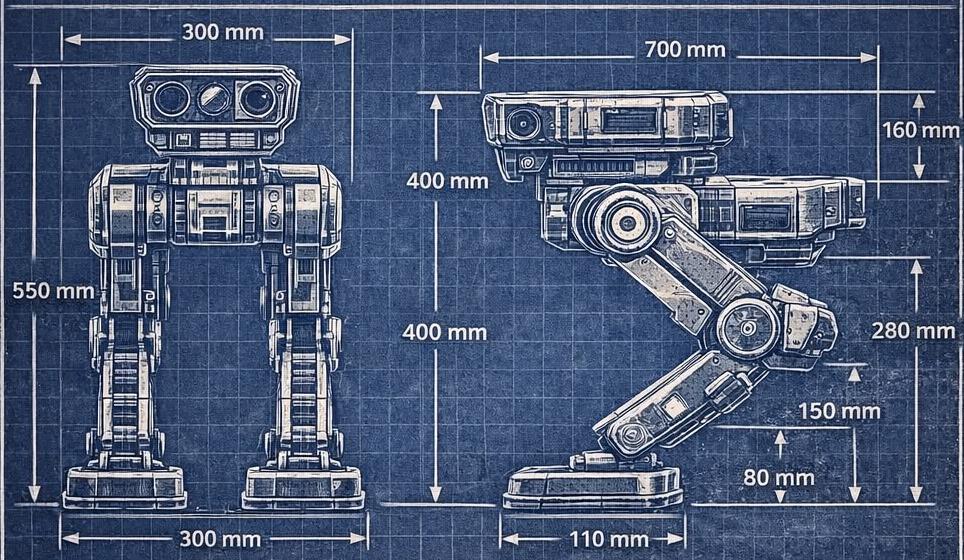
Mechanical chassis design (6061 aluminum), modular tracked and 12-DOF quadruped robotic platforms, sensor mast integration, and field hardware.
Artificial Intelligence
Computer vision, YOLOv8 real-time object detection, Kalman Filter multi-target tracking, and thermal hotspot sensor fusion.
Autonomous Systems
Navigation, 3D LiDAR point-cloud mapping, mission coordination, real-time telemetry, and autonomous operation research.
Embedded Systems
NVIDIA Jetson Orin Nano, Raspberry Pi 5, CM5, ESP32, Maixduino K210, firmware, and MIPI CSI / I2C / UART sensor interfaces.
Engineering Software
REVEROB OS central robot management, system architecture, field operator interface, 2FA cybersecurity, and OTA update infrastructure.
Research & Development
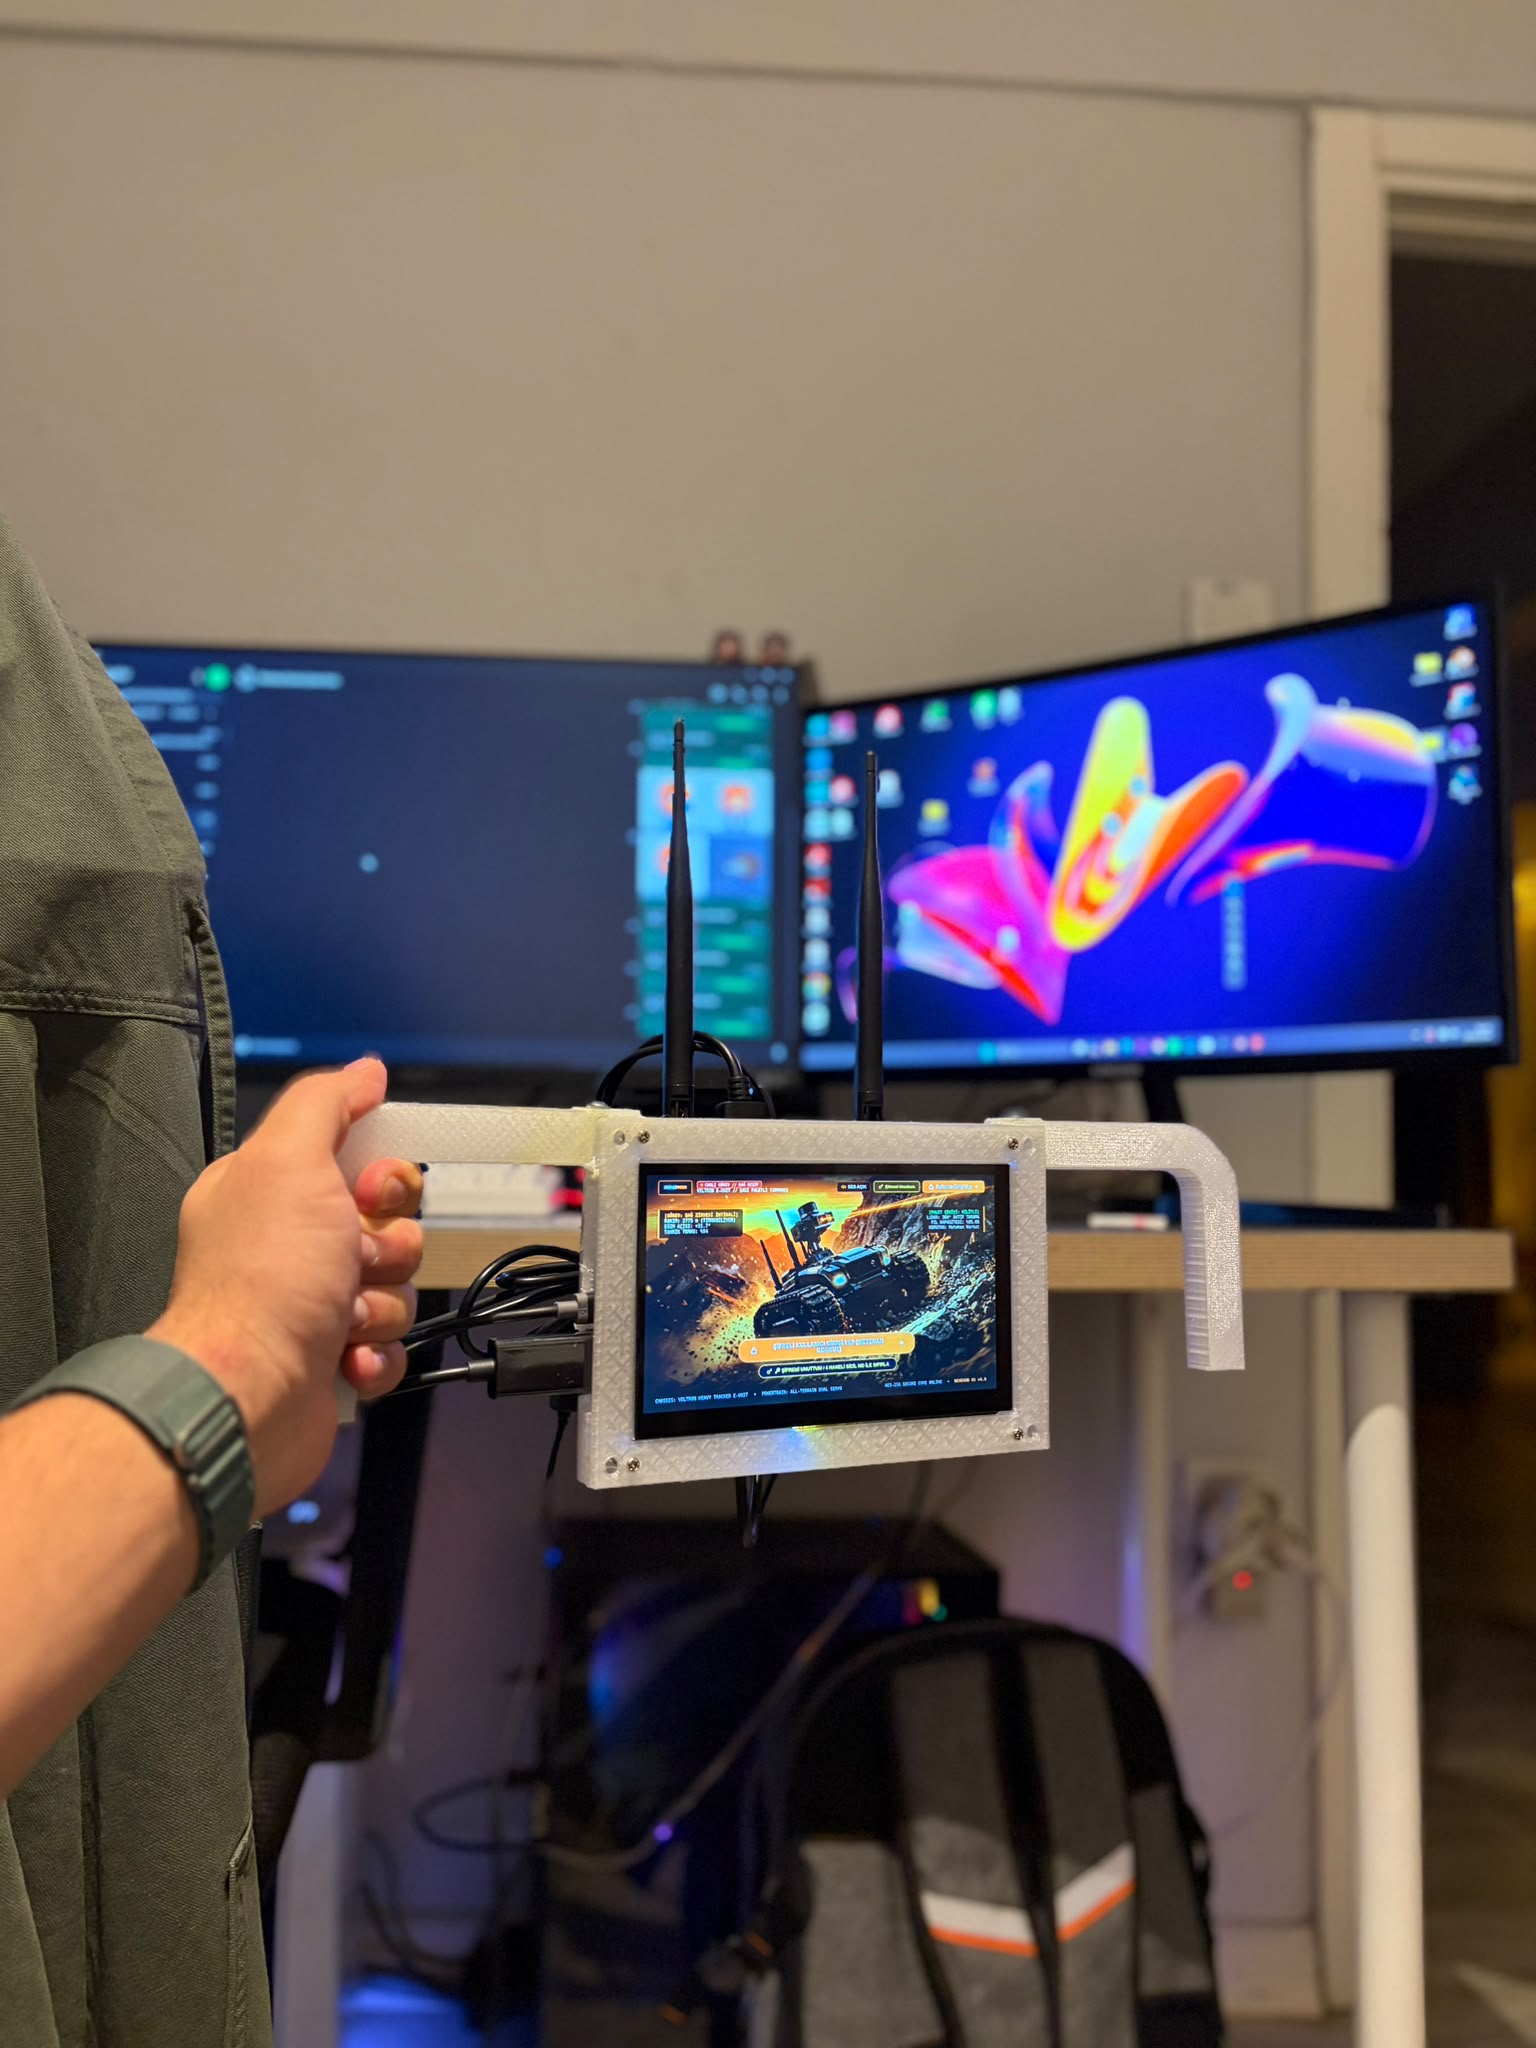
CAD modeling, additive manufacturing (FDM/Resin), experimental micro-turbine propulsion tests, portable ground control stations, and validation.
The REVEROB Engineering Portfolio
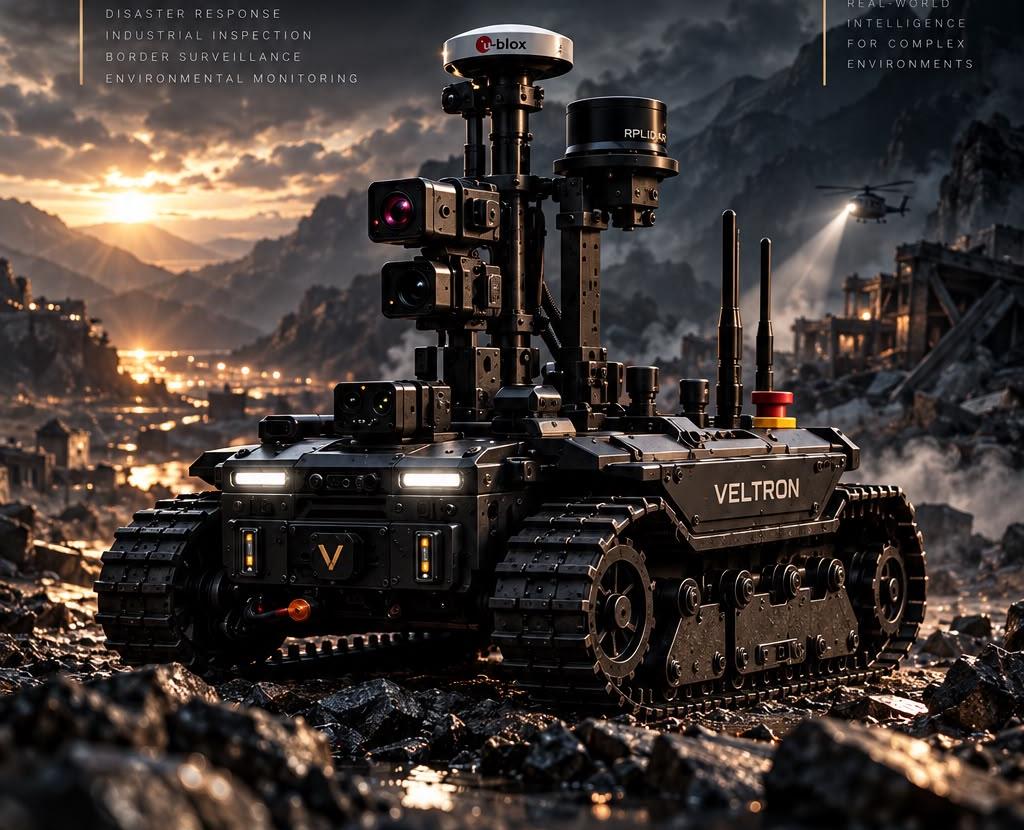
VELTRON UNIT X1
Modular Tracked Field Robotics Development Project
A modular tracked robotic platform developed around intelligent perception, multi-sensor integration (IMX477 CSI, AMG8833 thermal, TFmini-S LiDAR, MQ-2 gas), and autonomous robotics research.
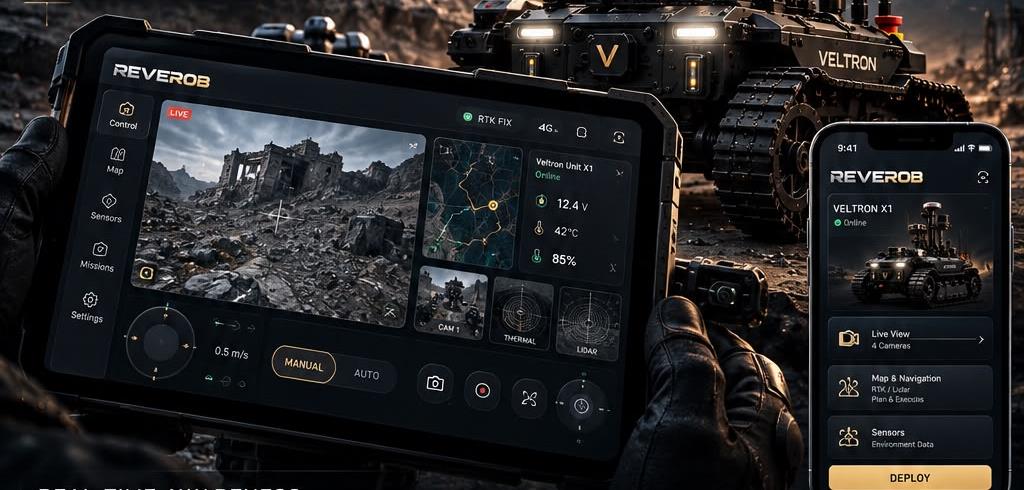
REVEROB OS & UPDATE CENTER
ExploreCentral robotics control platform built around React, Electron, Jetson Orin Nano target architecture, Raspberry Pi nodes, YOLOv8, and Kalman Filter tracking.
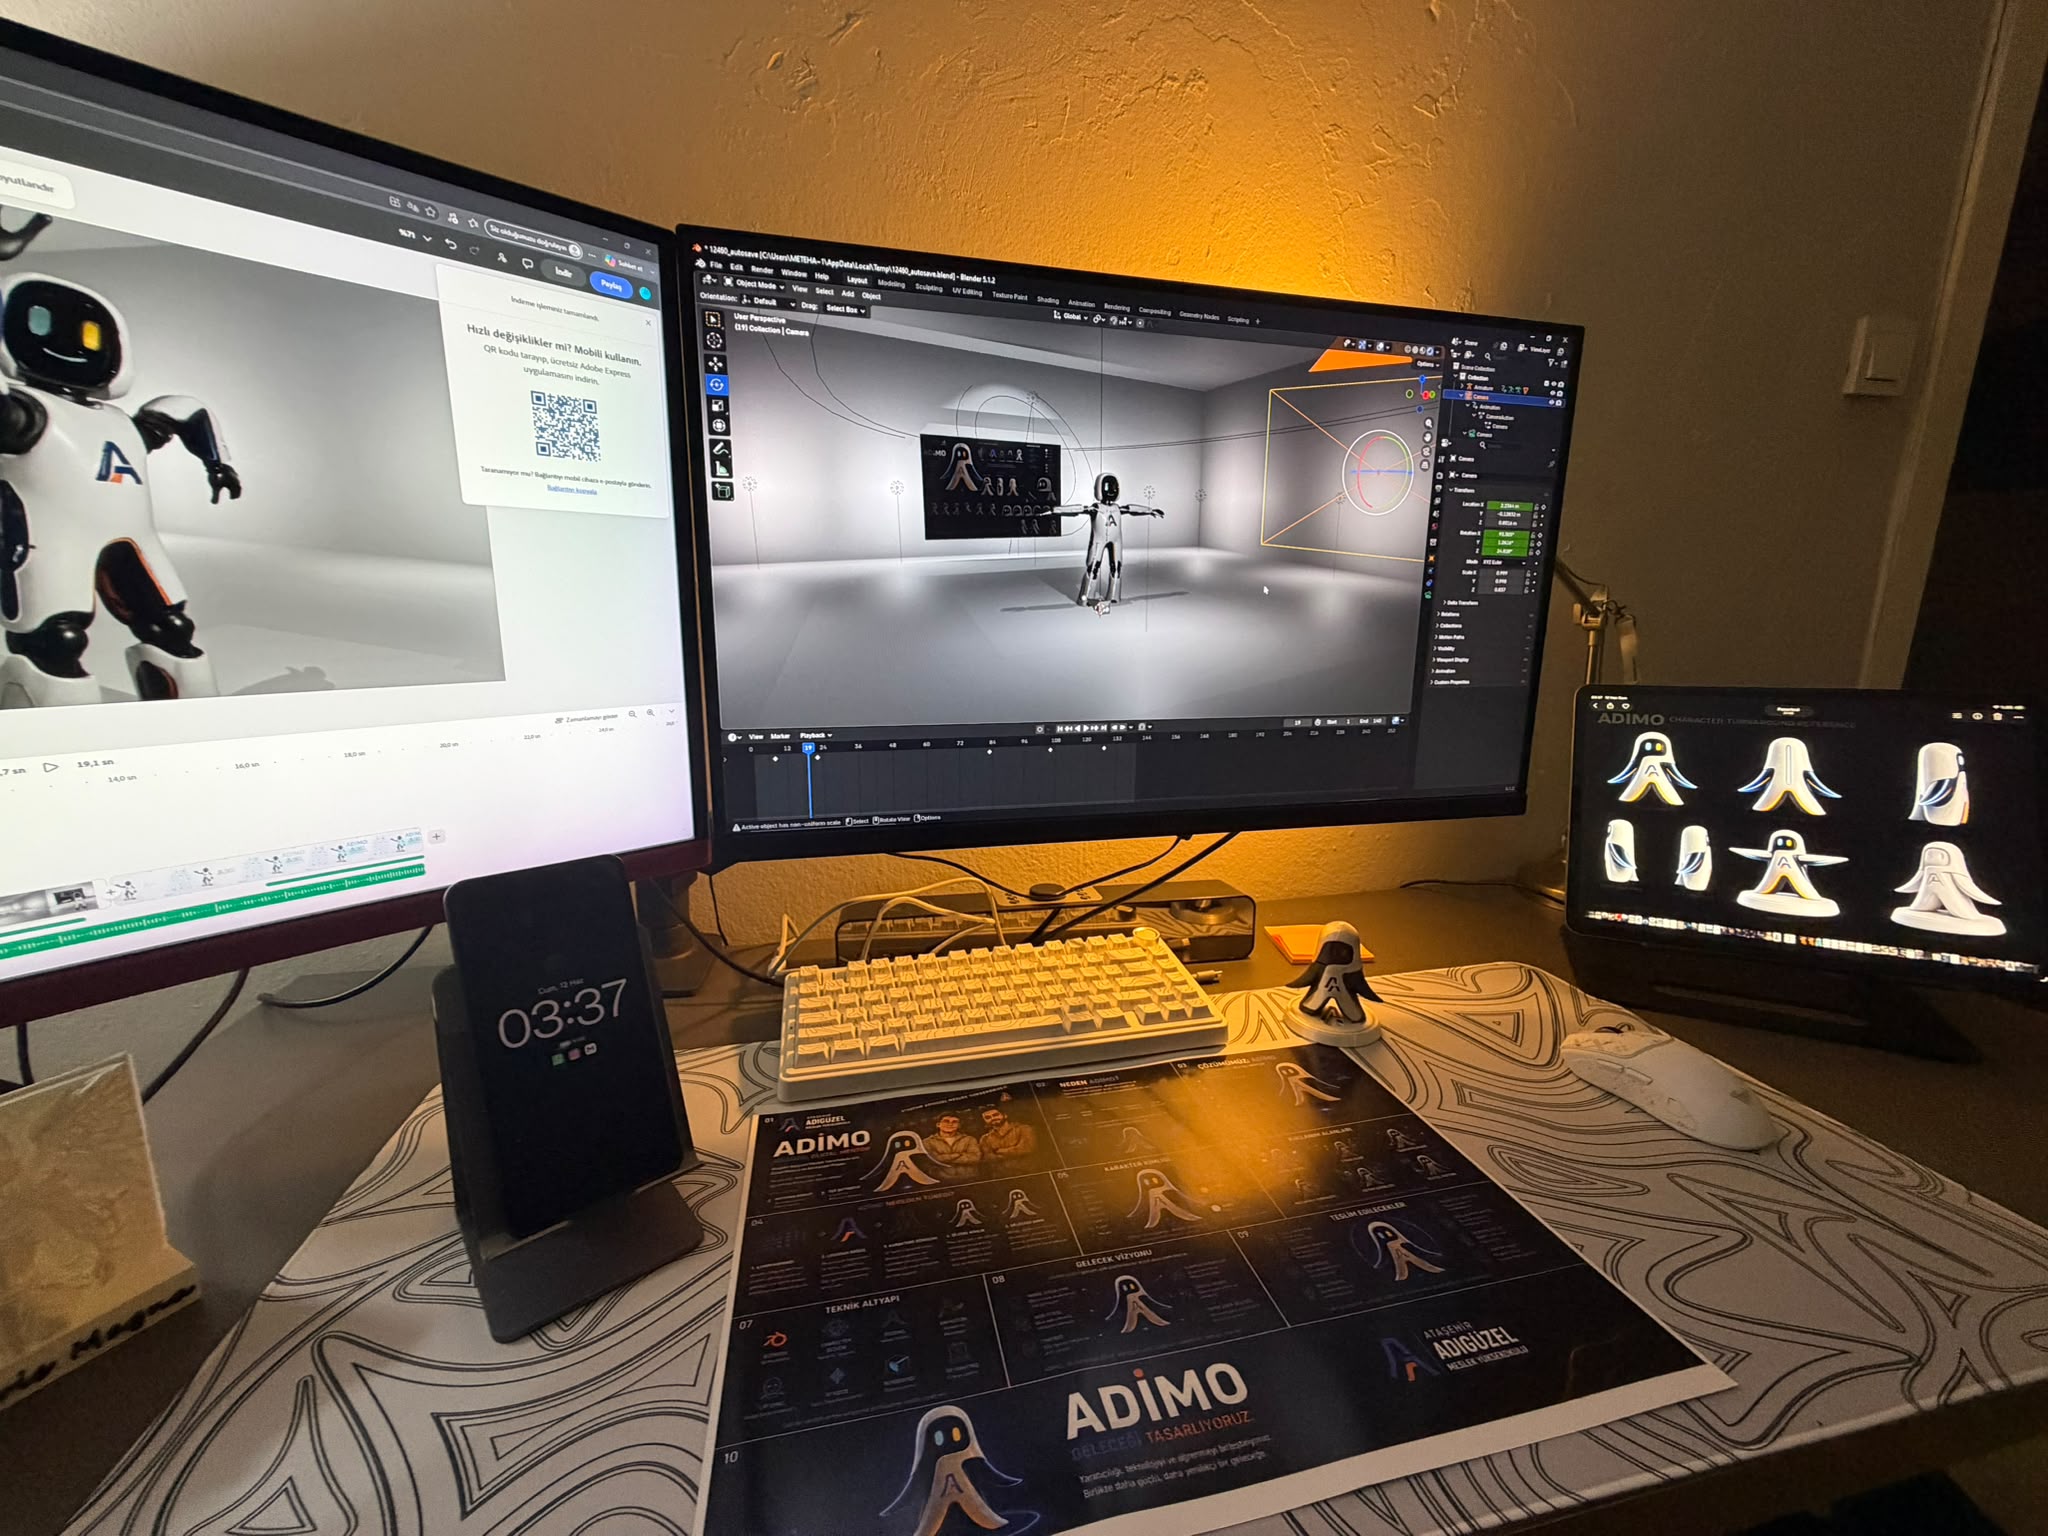
ADIMO PROJECT
Portfolio3D character design, technical illustration (200x200mm), Blender 5.1 modeling, and animation project associated with Ataşehir Adıgüzel MYO.
Robotics Command, AI Vision & OTA Infrastructure.
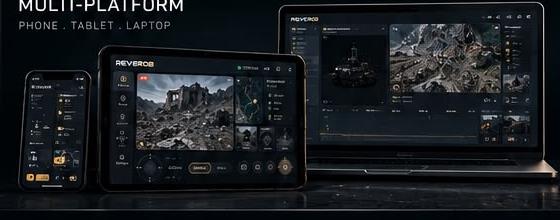
REVEROB OS is a modular robotics management and control platform designed to coordinate robotic devices, intelligent processing, and software infrastructure.
Central AI Compute & Local Robot Node Coordination
NVIDIA Jetson Orin Nano performs high-level AI processing and mission coordination, while Raspberry Pi 5 robot nodes and local controllers maintain low-level control and safety functions.
REVEROB OS & OPERATOR UI
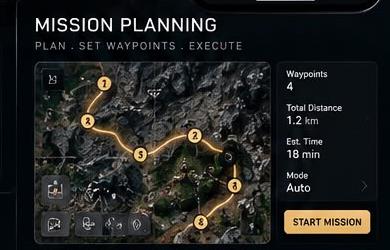
React & Electron command interface, mission planning, 2FA security center, and OTA Update Center.
NVIDIA JETSON ORIN NANO
High-level AI inference (YOLOv8), Kalman Filter object tracking, 3D mapping, and mission coordination target.
RASPBERRY PI 5 NODES
VELTRON primary onboard compute: sensor fusion, local decision loops, safety interlocks, and low-latency control.
SENSORS & ACTUATION
IMX477 CSI camera, AMG8833 thermal, TFmini-S LiDAR, MQ-2 gas sensor, IMU, encoders, motor drivers, and GPIO.
From Drafting Paper to Prototype: 7-Stage R&D Pipeline
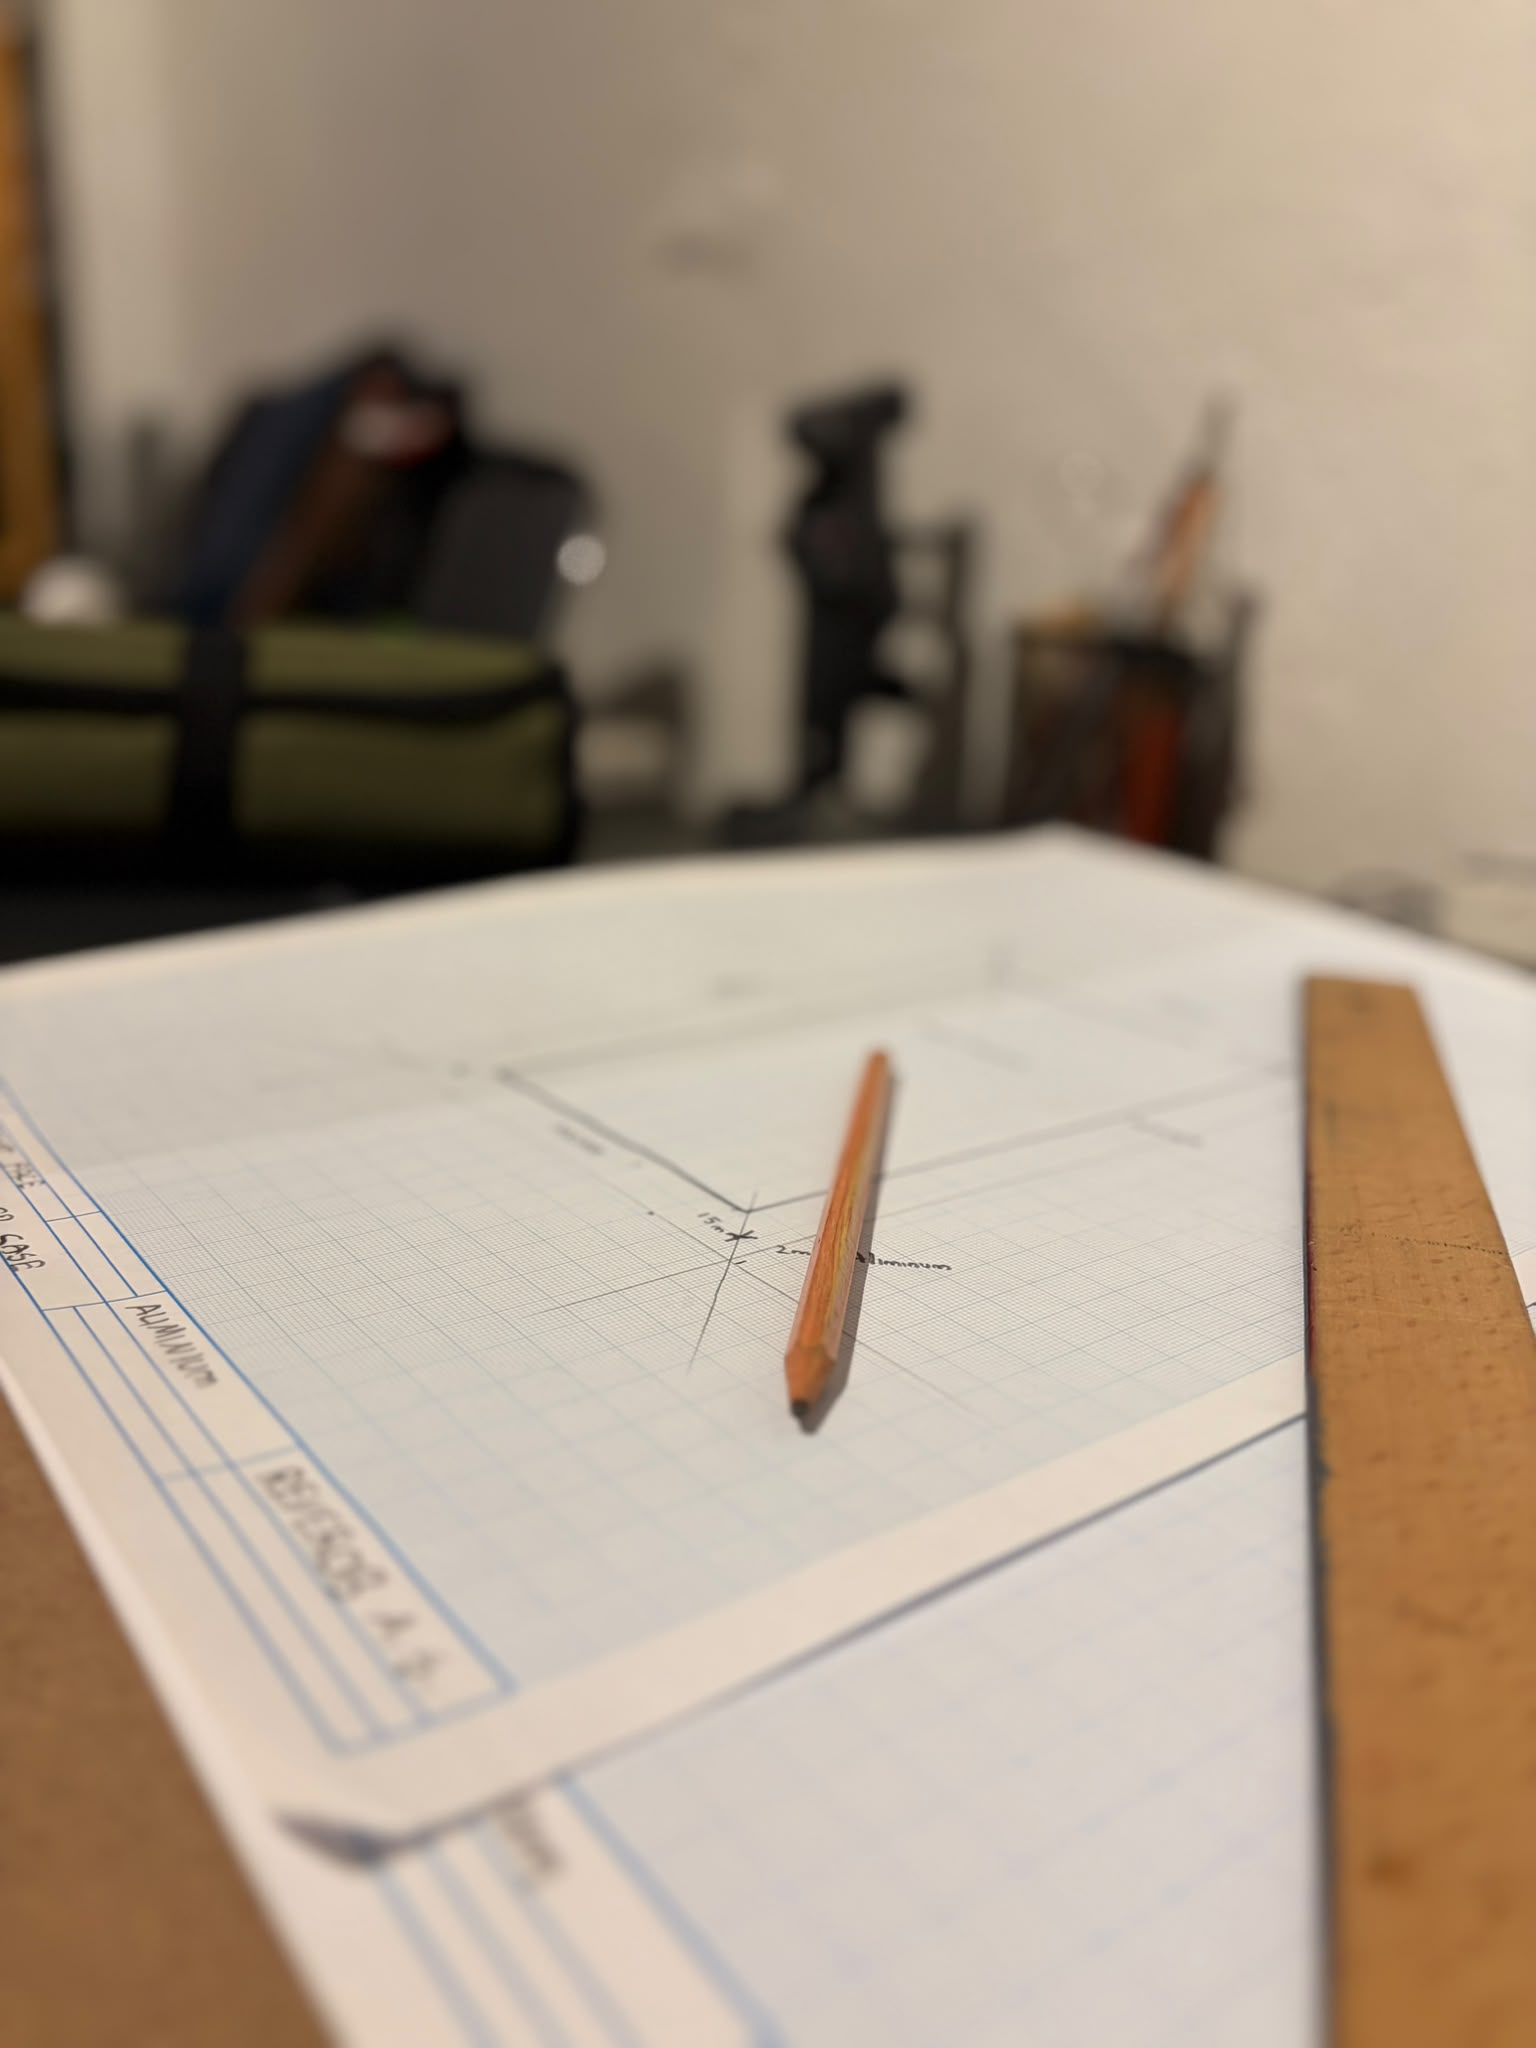
Concept Design
Mechanical drafting & aluminum chassis planning
System Architecture
Perception, decision & actuation layer topology
Hardware Development
3D CAD modeling, sensor bays & PCB selection
Software Integration
REVEROB OS, YOLOv8 & Kalman Filter integration
Prototype Assembly
Fabrication, wiring & mechanical sub-assembly
Testing & Validation
Bench testing & multi-sensor calibration
Iterative Improvement
Continuous architectural refinement
REVEROB // CORPORATE MANIFESTO
“Engineering the Autonomous Future. We Engineer Intelligent Machines for the Real World.”
REVEROB unites physical robotic platforms, embedded computing, artificial intelligence perception, and modular control software under a single engineering discipline.
Initiate a Project, R&D or Technology Collaboration.
Connect with our engineering team regarding robotic platform development, embedded systems integration, REVEROB OS architecture, and R&D initiatives.